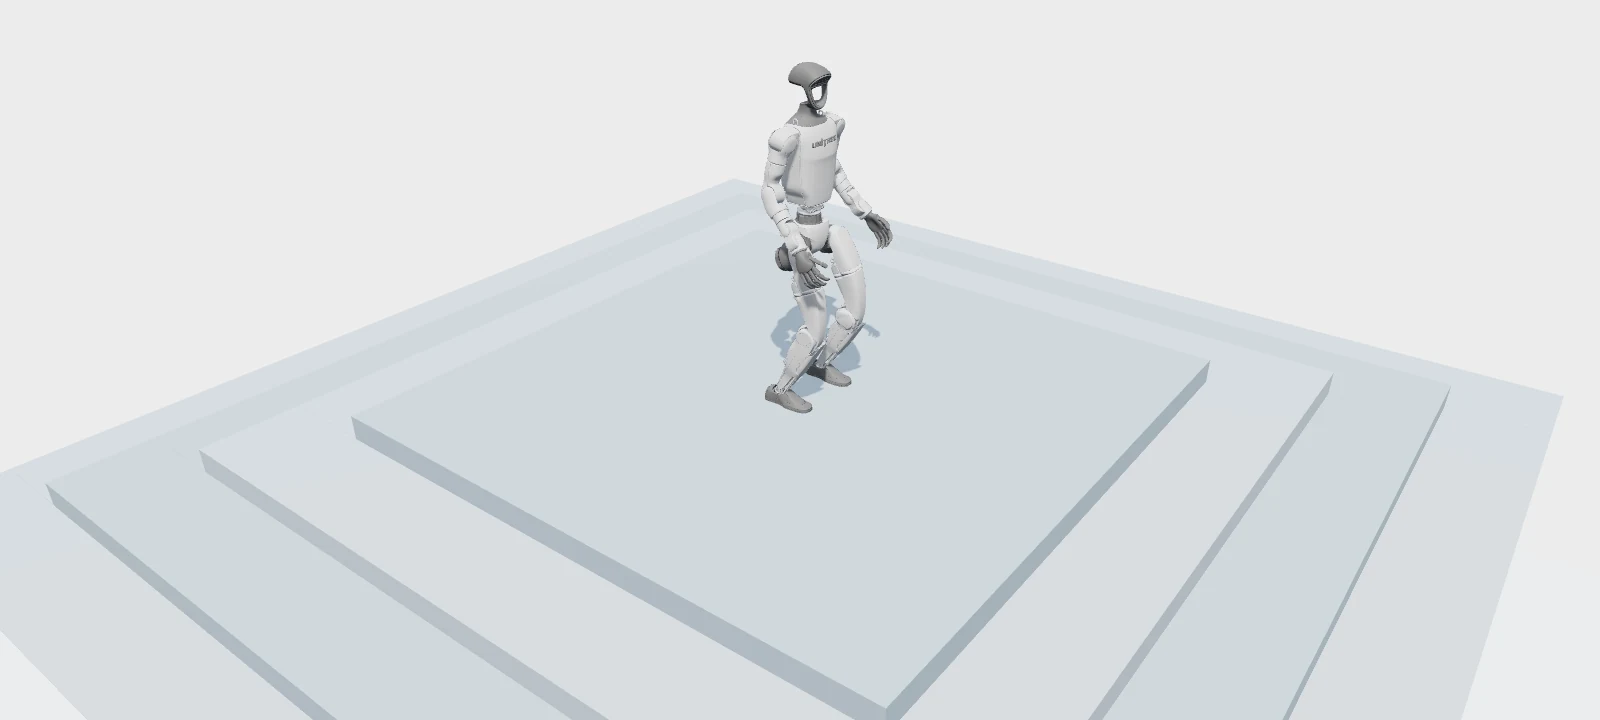
Live human motion in. Terrain-aware humanoid behavior out.
NEXUS takes its name from the connections it builds—between human and robot, expressive
motion and perceptive control—with a vision of carrying human intent across terrains,
not just across embodiments.
NEXUS IN THE REAL WORLD
Experiment Gallery
Human intent, different terrain. Explore whole-body behaviors across indoor obstacles
and outdoor environments.
Select a clip to watch in a larger player. Clips retain the supplied footage’s playback
speed.
Interactive Demo
Try NEXUS in your browser. Choose a motion and terrain, then watch the robot respond.
Explore diverse motions—from walking and dancing to squatting, kneeling, and
jumping—across flat ground, stairs, slopes, rough terrain, waves, and random
platforms. Customize the terrain, import your own motion file, and try new
combinations.
Opens in a new tab Best experienced in a desktop browser · Initial loading may
take a few seconds.
Abstract
Whole-body teleoperation requires a humanoid robot to reproduce a human operator's
behavior even when their terrains differ. This demands that the robot perceive local
terrain and adapt its posture and contacts accordingly, rather than copy the
operator's motion frame by frame. However, paired motion data linking the same
behaviors across flat ground and different terrains remain scarce, limiting
supervision for learning terrain-adaptive control.
To enable whole-body teleoperation across mismatched terrains, we introduce
NEXUS, a perceptive whole-body control framework that combines human
motion commands with onboard sensory feedback. We first develop a scalable
terrain-aware adaptation algorithm that efficiently generates high-quality motion
pairs across motions and terrains without per-motion or per-terrain tuning. Using a
paired motion corpus totaling nearly 1,000 hours, we train a perceptive whole-body
controller through teacher–student learning to reproduce commanded behaviors across
terrains.
Experiments demonstrate efficient, scalable generation of high-quality motion data and
show that NEXUS combines broad behavioral coverage with terrain adaptability and
tracking fidelity, outperforming existing whole-body controllers on the evaluated
benchmarks. Zero-shot real-world deployment enables real-time whole-body teleoperation
on diverse unseen terrains, further validating the generalization of our method.
Method
From offline motion adaptation to perceptive policy learning and zero-shot deployment.
01 / Motion adaptation
Build paired motion references
Detect foot and hand contacts in a flat-ground motion, adjust
pelvis height to the terrain, and solve inverse kinematics at contact keyframes with
penetration correction. Interpolating the pose corrections reconstructs a
terrain-adapted trajectory aligned frame by frame with the original
command.
02 / Policy learning
Learn how terrain changes motion
A privileged teacher learns to track adapted references using
reinforcement learning (PPO). DAgger-style imitation then trains a student with the
paired flat-ground command, proprioceptive history, and a depth
image. The paired data connect the operator’s intent to the behavior required on the
robot’s terrain.
03 / Deployment
Adapt with onboard perception
At deployment, streamed human motion is
retargeted to the robot in real time to form the motion command.
The student combines this command with
onboard depth and proprioception to produce joint-position targets.
Terrain-adapted references are used only during training; at inference, terrain
adaptation relies on robot-side perception.
What NEXUS Enables
From a flat-ground human command to whole-body behavior on the robot’s terrain.
Nearly 1,000 h
Paired motion supervision
A motion corpus including terrain-adapted variants connects human behaviors to the
posture and contacts needed on different support surfaces.
Hands + feet
Whole-body terrain adaptation
Contact-guided adaptation handles both foot and hand support, adjusting contacting
limbs while preserving motion in the rest of the body.
Real-time
Perceptive whole-body teleoperation
Streamed human motion, onboard depth, and proprioception drive terrain-adaptive
behavior in real time.
One adaptation pipeline, diverse motions and terrains. The same
configuration generates paired references across ascending and descending stairs and
slopes, without per-motion or per-terrain tuning. The controller learns from these
pairs so that the operator can stay on flat ground while the robot responds to its own
surroundings.
Beyond locomotion. Real-world demonstrations span walking, crouching,
squatting, kneeling, kicking, single-leg balance, jumping, and cartwheels. The human
supplies the behavior; NEXUS uses robot-side perception to adapt its execution.
Motion adaptation across terrains. Selected frames from a composite
sequence assembled from multiple motion clips. Rows show the flat-ground source and
its kinematic adaptations to stairs, a slope, and wavy terrain; columns compare poses
at the same time. Click the image to inspect the full-resolution comparison.
Zero-Shot Real-World Deployment
Real-time whole-body teleoperation under
human–robot terrain mismatch across indoor and outdoor terrains,
without fine-tuning.
NEXUS transfers from simulated training to whole-body teleoperation on a Unitree G1,
including (a) stair ascent followed by stepping down from a 60 cm platform; (b) a
cartwheel across a platform edge; (c) single-leg balancing on a ramp and a step,
double-knee kneeling and vertical jumping on indoor platforms, outdoor stair climbing
and squatting, and single-knee kneeling and kicking on grassy slopes.
Policy inference runs onboard a Jetson Orin NX at 50 Hz, using depth images from an
Intel RealSense D435i. Human poses are retargeted on a separate PC and streamed to the
robot, where the policy combines them with local depth and proprioception.
Although training terrains contain only 10 cm steps and slopes of approximately 16.7°,
NEXUS transfers without fine-tuning to continuous ascent of 15 cm stairs, grassy
slopes reaching approximately 30°, and stepping or jumping down from a 60 cm platform.
It also performs cartwheels on indoor ramps and stairs and on outdoor grassy slopes.
In our trials, no failures were observed during routine pose tracking; falls occurred
during some drops from the 60 cm platform and cartwheel attempts.
Current scope. The motion adaptation algorithm does not support
overhanging terrain. Extending its geometric coverage and connecting the controller to
task-level planners are directions for future work.
Citation
@misc{miao2026nexus,
  title = {{NEXUS}: Perceptive Whole-Body Control for Terrain-Adaptive Teleoperation},
  author = {Xiangyu Miao and Junsong Wu and Jiyuan Shi and Weiji Xie and Jinrui Han and Xingyi Wang and Weinan Zhang and Chenjia Bai and Xuelong Li},
  year = {2026},
  eprint = {2609.39000},
  archivePrefix = {arXiv},
  primaryClass = {cs.RO},
  doi = {10.48550/arXiv.2609.39000},
  url = {https://arxiv.org/abs/2609.39000}
}